Prosthetic Hand
Aim
Explore how hand tracking can control a physical robotic hand, building practical experience in hardware, servo actuation and software integration using a publicly available mechanical model.
Solution
The prosthetic hand features a lightweight, modular design with intuitive control mechanisms. It incorporates advanced materials and manufacturing techniques to ensure durability and comfort, while providing a wide range of motion and functionality.
Project Links & Attributions
The Process
The project connected an existing mechanical design with servo actuation and hand-tracking software, with my work focused on building and integrating the physical system.
Research
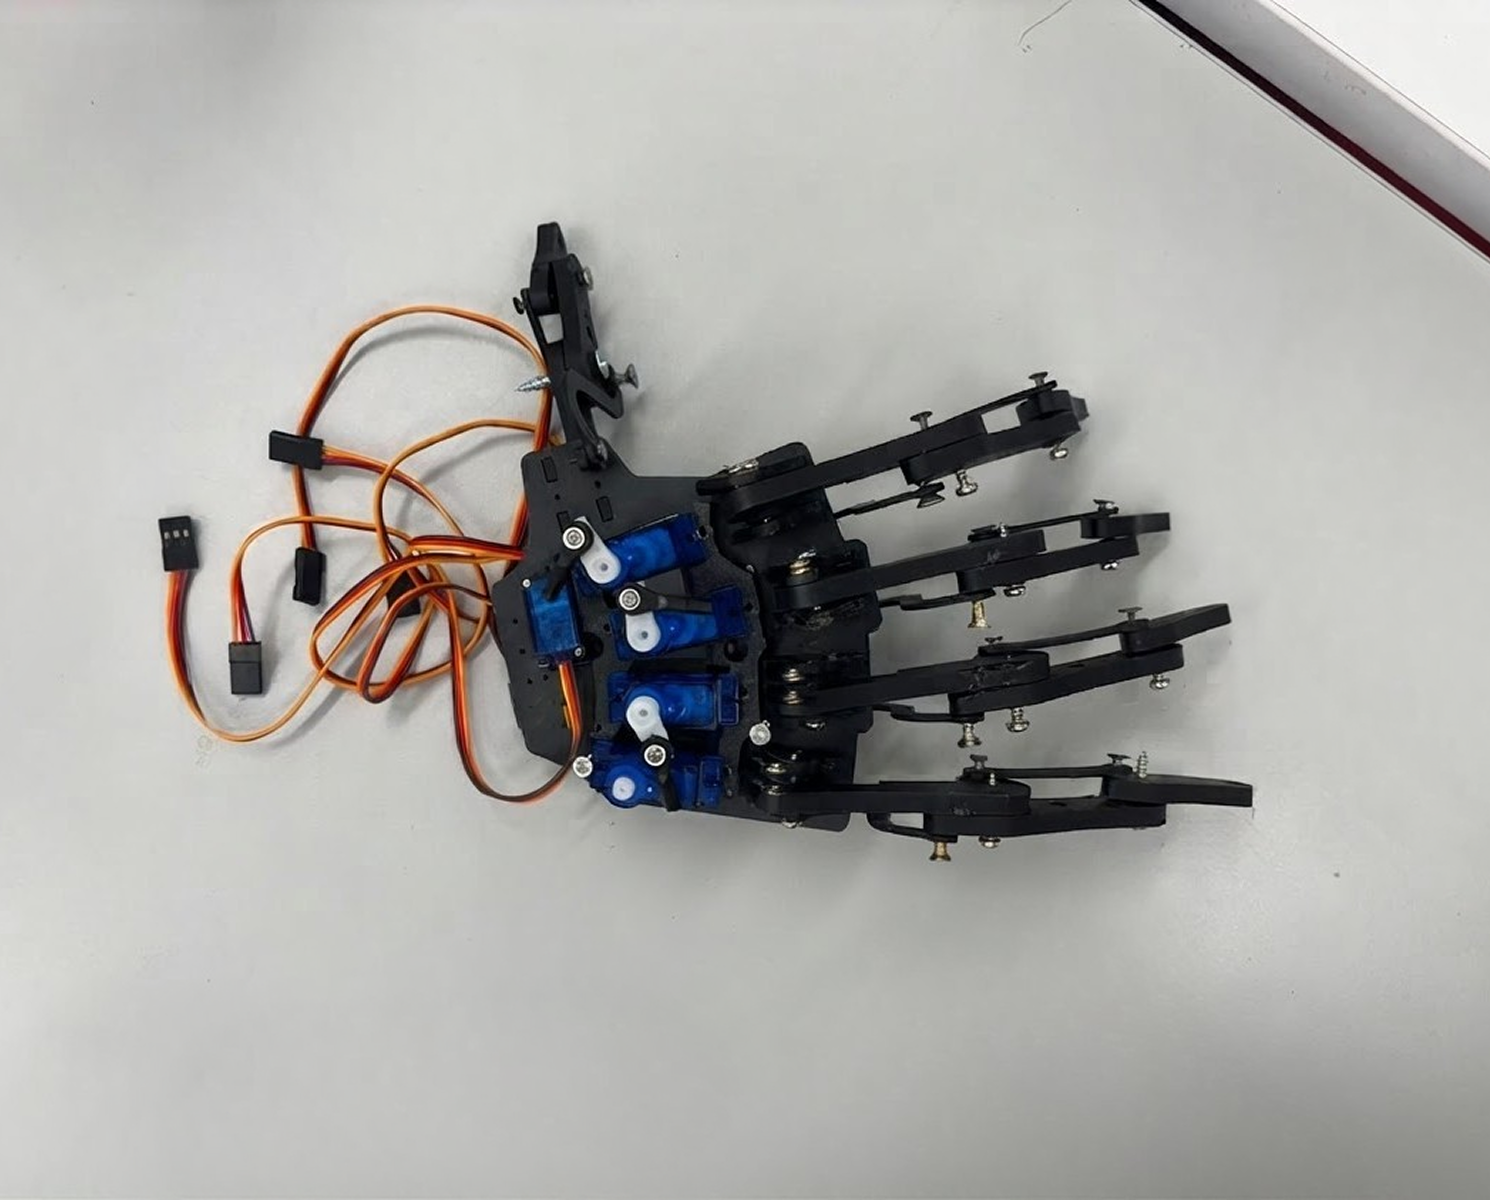
The publicly available Bionic Robot Hand model provided the mechanical starting point. The exploration focused on how its finger linkages could be actuated and connected to a control system.
Servo Integration
I led the hardware and servo integration. Five SG90 micro servos provide individual finger actuation, connecting the control signals to movement through the hand's mechanical linkages.
Hand Tracking & Response
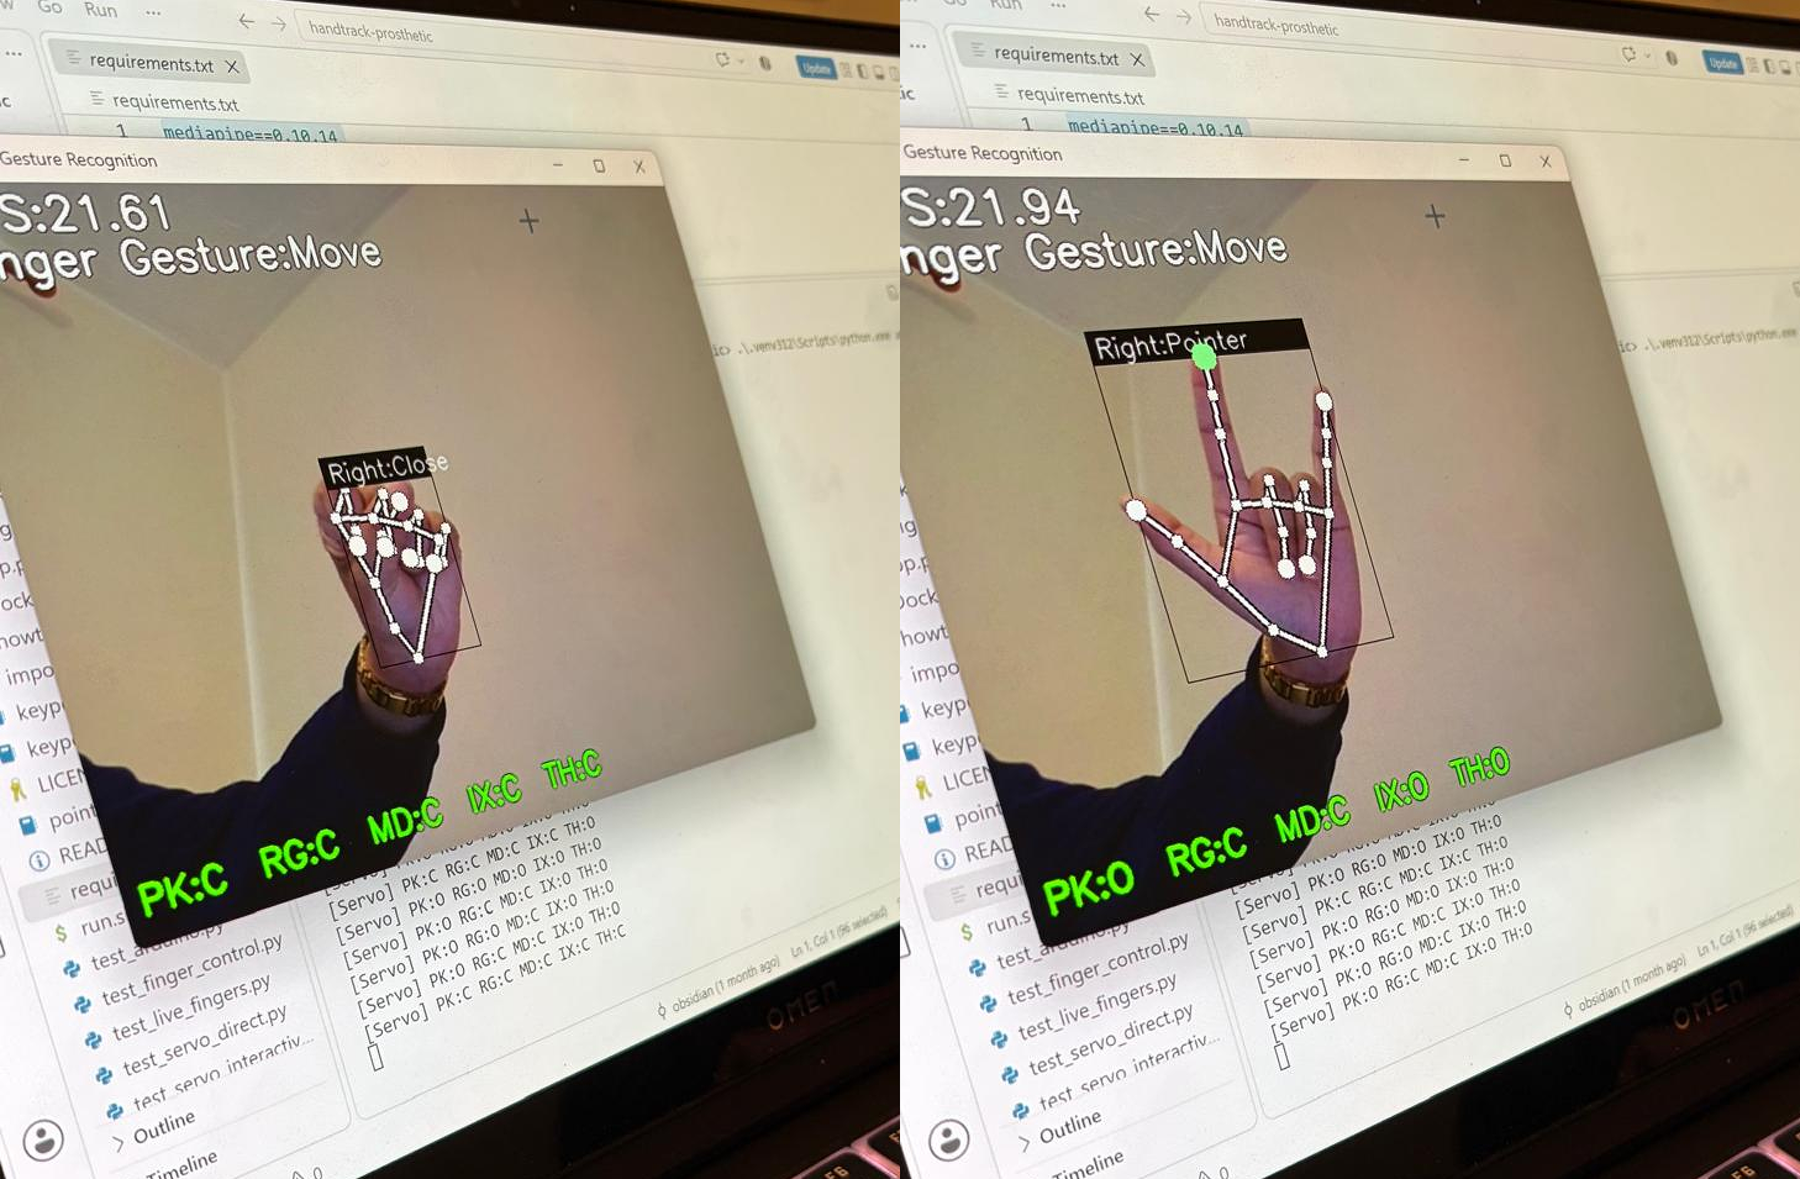
My partner led the software development, with substantial coding contributions from me. MediaPipe hand landmarks are mapped to finger states and sent to the Arduino, linking the webcam input to the physical mechanism.